
ARC WORLDS
More situations.
Before the real run.
Run robot policies through repeatable simulated tasks, environments, and perturbations. Discover failures where an experiment can be reset and inspected.
AUTONA ROBOT CLOUD / SIMULATION
- START WITH
- Policy, robot twin, scenario collection
- WORK TOWARD
- Rollouts, outcomes, and failure replays
- BUILT FOR
- Simulation and evaluation teams
The same policy. Different worlds.
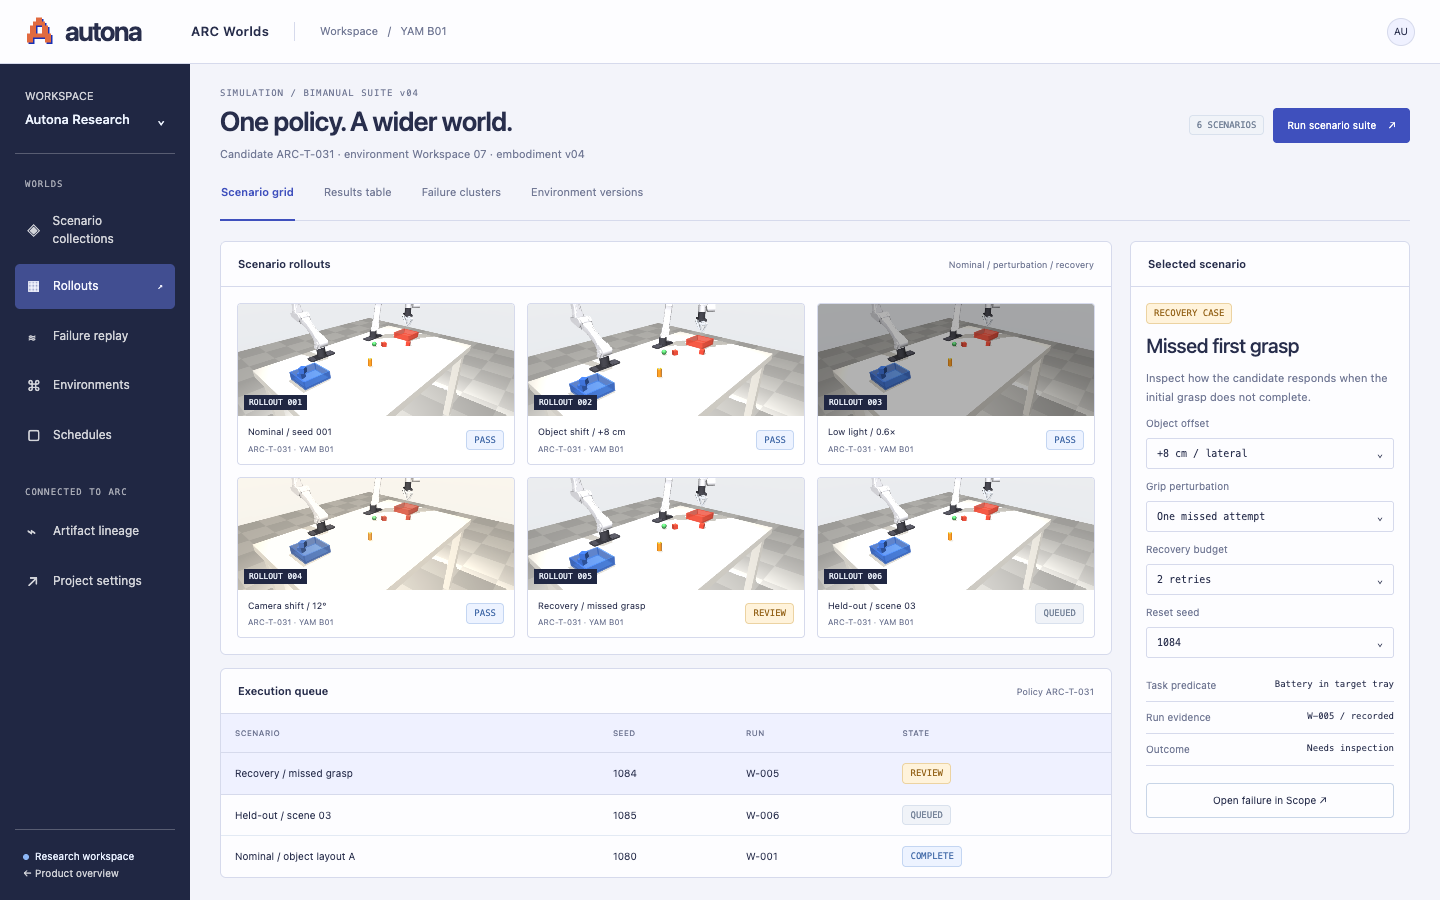
A rollout workspace that compares nominal, perturbed, and recovery scenarios, with failures and their evidence ready for inspection.
Test the task.
Then change the world.
One clean rollout is a starting point. Worlds is designed to explore how a policy behaves when the setting changes and the expected path stops working.
Assemble a scenario
Combine a robot twin, a candidate policy, a task definition, and a versioned environment.
Run the variations
Execute the candidate across the scenario collection and record task outcomes and interventions.
Feed evidence forward
Inspect failures with Scope and pass comparable outcomes to Gauntlet for the release decision.
Find out before your robot does.
Tell us about your robot, your team, and the problem you want to solve.