
ARC SYNTH
Capture a space.
Build a world.
Turn video and image capture into reusable 3D environment collections. Give robot learning and simulation a connection to the places that matter.
AUTONA ROBOT CLOUD / RECONSTRUCTION
- START WITH
- Video, images, environment capture
- WORK TOWARD
- Versioned 3D environment assets
- BUILT FOR
- Simulation and robot-learning teams
From capture to a reusable scene.
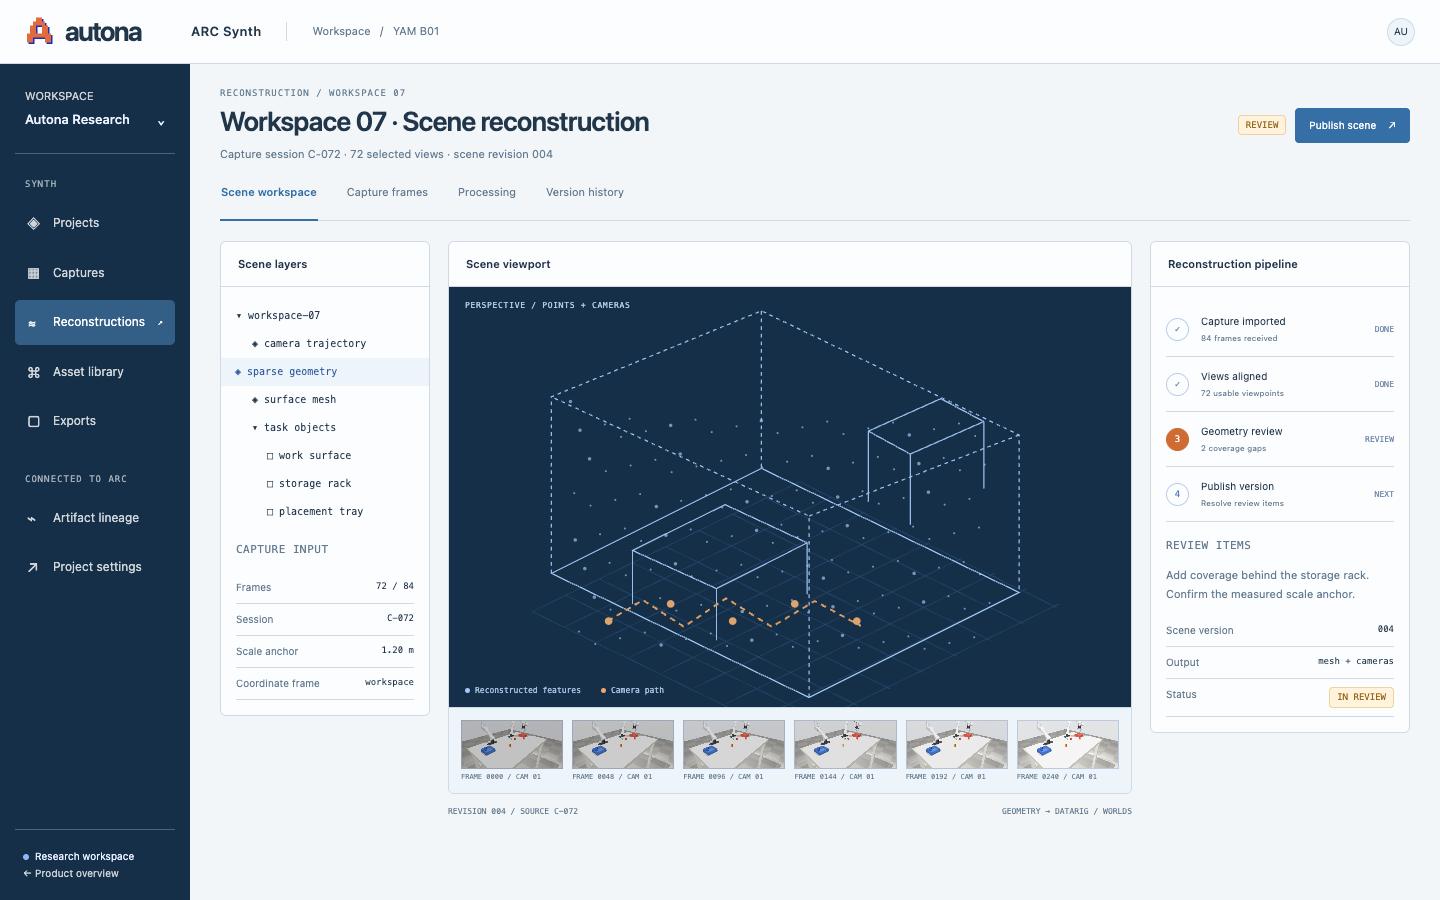
A reconstruction workspace with a scene view, camera path, capture frames, processing stages, and the review steps before publishing an environment.
Bring the environment
into the learning loop.
A generic scene is rarely the place your robot needs to work. Synth is designed to bridge accessible real-world capture and reusable environment assets.
Capture or import
Start with video and images of the environment and the task-relevant surfaces and objects.
Reconstruct and review
Create a 3D representation, inspect coverage, and identify where additional capture or cleanup is needed.
Publish a versioned world
Package the environment for use in Datarig and Worlds with its provenance and reconstruction context.
Bring your environment into ARC.
Tell us about your robot, your team, and the problem you want to solve.