
ARC NESS
A mission needs
more than a model.
Run robot policies inside a mission-aware harness. Coordinate execution, action boundaries, observations, recovery, and the evidence that a task actually finished.
AUTONA ROBOT CLOUD / ROBOT RUNTIME
- START WITH
- Deployment bundle and task instruction
- WORK TOWARD
- Supervised missions and runtime telemetry
- BUILT FOR
- Robot developers and deployment teams
Follow the mission through.
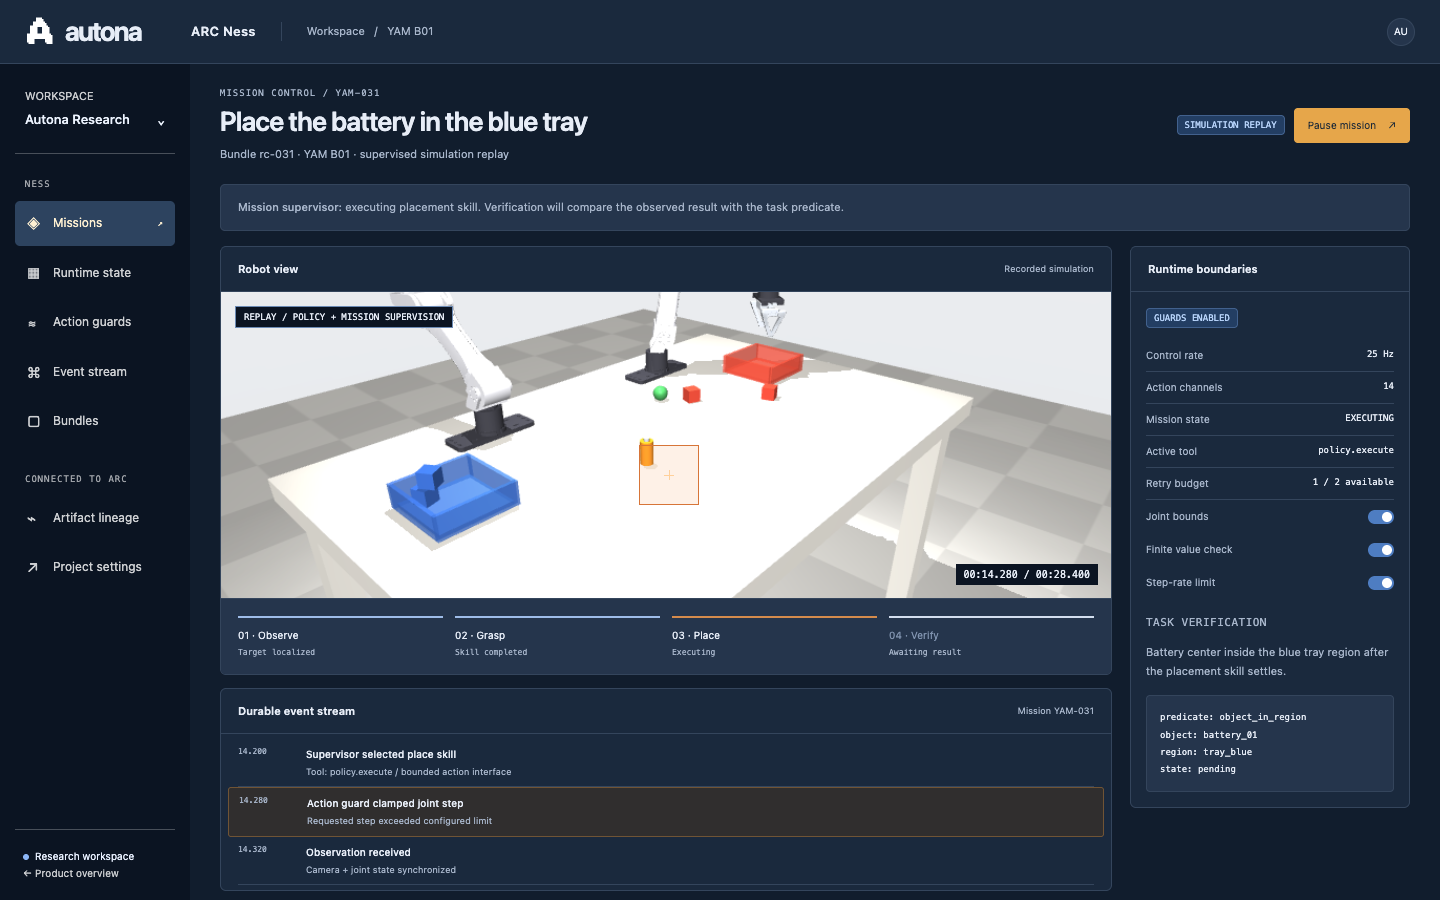
A mission-control workspace connecting simulation replay, supervisor state, guarded execution, task verification, and a durable event stream.
Plan. Act.
Check what changed.
Loading a policy is only one part of operation. Ness connects high-level mission reasoning with bounded control, durable events, and explicit task verification.
Load the mission
Load the robot bundle, task instruction, runtime configuration, and expected completion criteria.
Execute with supervision
Coordinate policy calls and bounded tools while tracking observations, interventions, and mission state.
Verify and learn
Check the observed result, record the outcome, and send the mission evidence back through Scope.
Give your robot a mission runtime.
Tell us about your robot, your team, and the problem you want to solve.