
ARC RELAY
Cloud intelligence.
Robot-side action.
Real-time cloud inference for robots. Host a compatible robot model, connect the observation stream, and receive model outputs through a managed endpoint. Define your checkpoint in ARC Tune.
AUTONA ROBOT CLOUD / REAL-TIME CLOUD INFERENCE
- START WITH
- A checkpoint from ARC Tune and robot observations
- WORK TOWARD
- Streamed inference through a model endpoint
- BUILT FOR
- Robot developers and deployment teams
An endpoint. A model. A robot.
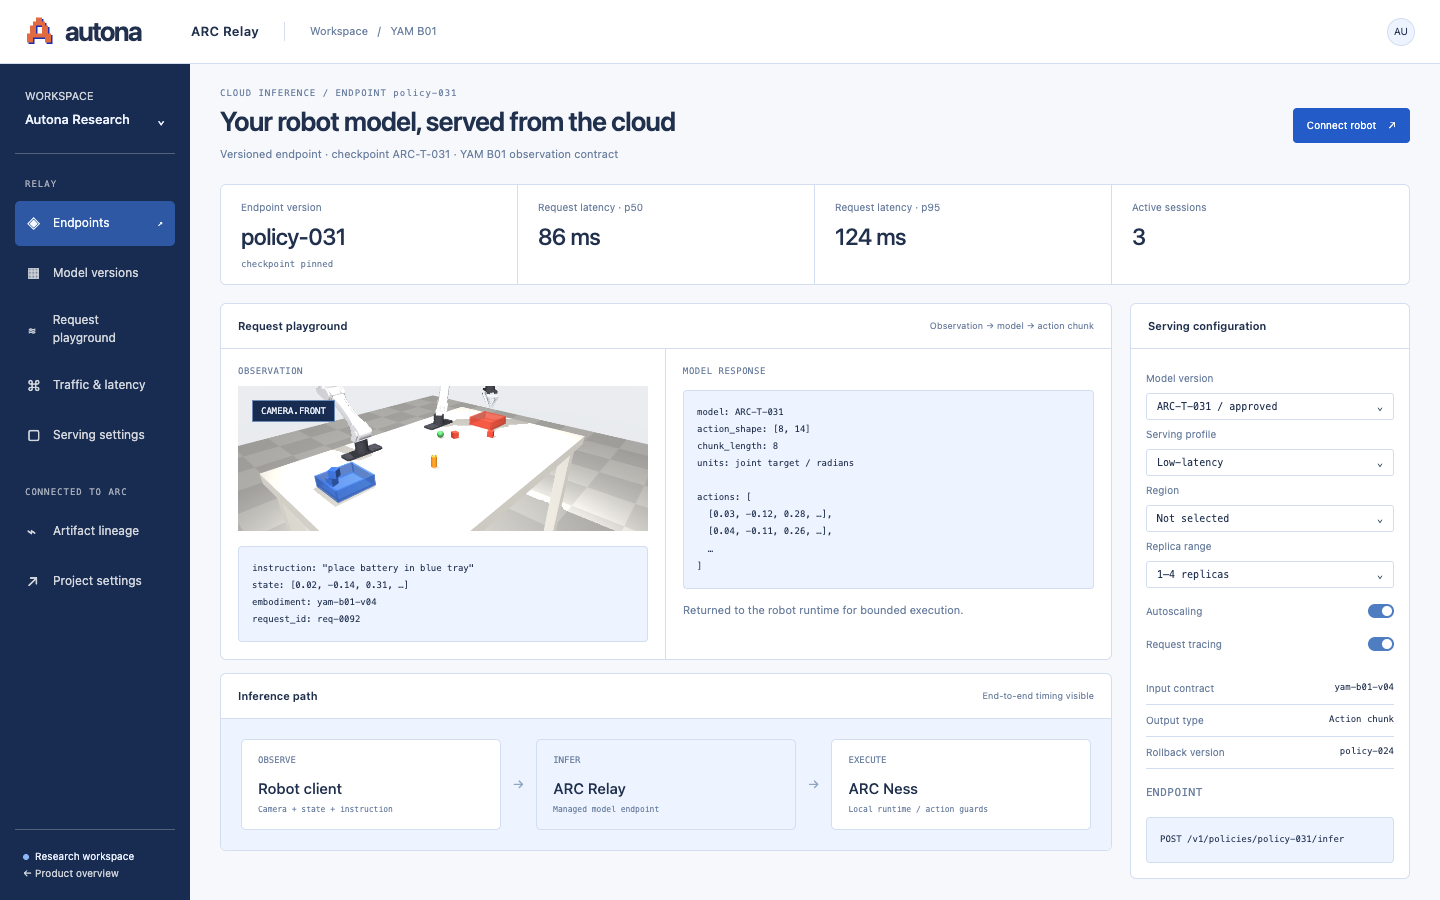
A cloud-inference workspace with a versioned policy endpoint, request playground, response inspection, serving settings, and latency diagnostics. Metrics shown are illustrative.
Run the model.
We handle the compute.
A working policy should not require every robotics team to become a GPU operations team. Relay is designed to connect managed model serving with the observation and action interfaces your robot already uses.
Define your checkpoint
Upload and define your checkpoint in ARC Tune, then select it for serving in Relay.
Connect the robot
Map the robot observations and returned policy outputs through its defined interface and adapter.
Serve and observe
Run cloud inference, inspect end-to-end timing and outputs, and connect the endpoint to Ness for supervised robot missions.
Connect your robot to cloud inference.
Tell us about your robot, your team, and the problem you want to solve.