
ARC DATARIG
Small seed.
Broader experience.
Expand demonstrations and task trajectories across variations in scenes, objects, cameras, and conditions. Build a richer training distribution from a smaller starting point.
AUTONA ROBOT CLOUD / DATA GENERATION
- START WITH
- Demonstrations, IK trajectories, scenes
- WORK TOWARD
- Versioned datasets with source lineage
- BUILT FOR
- Data and robot-learning teams
A dataset recipe you can inspect.
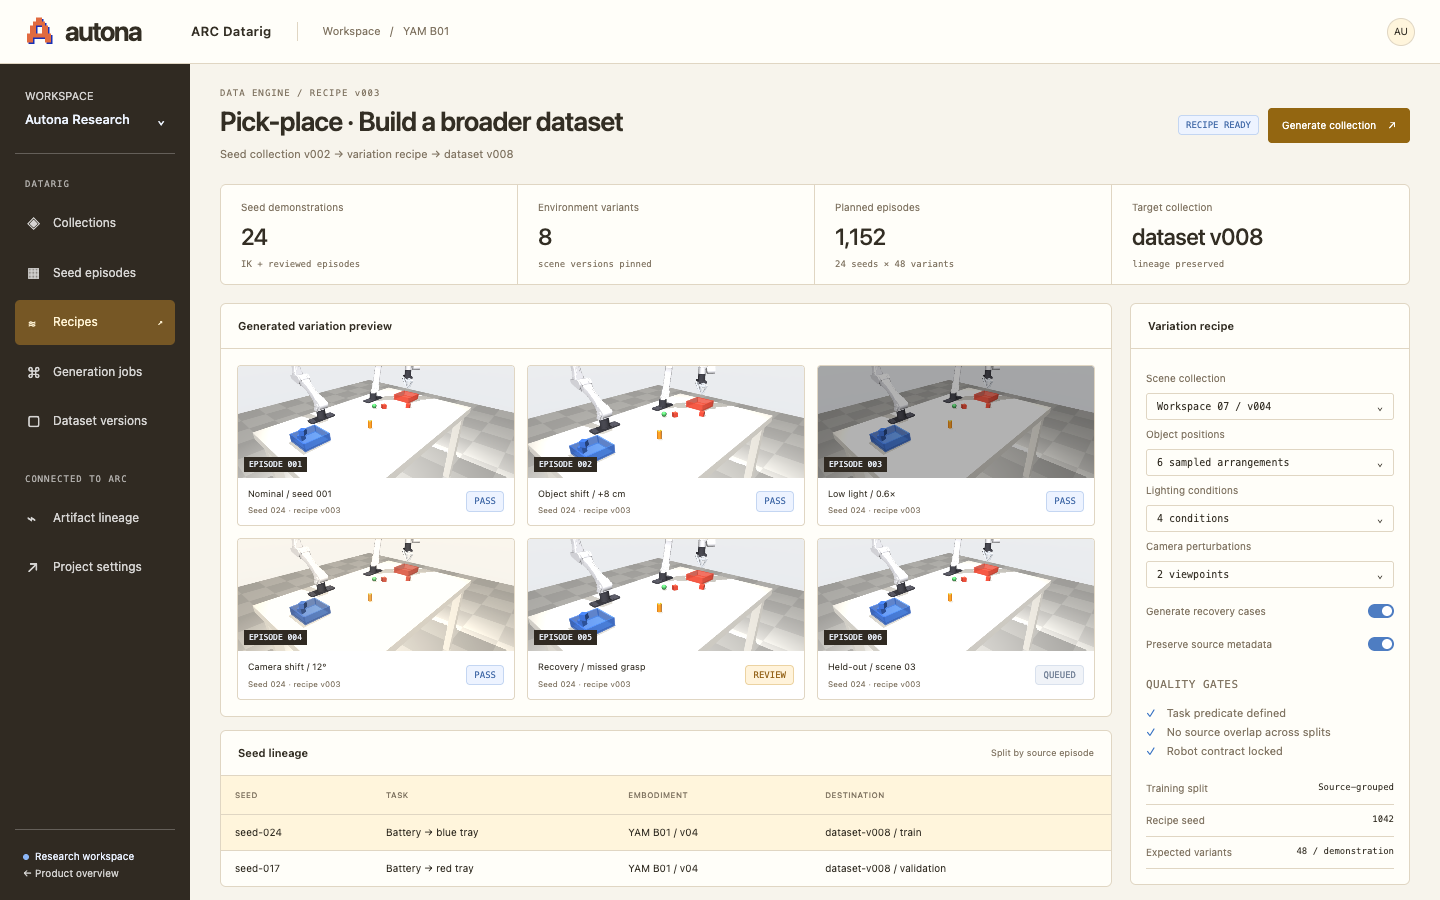
A seed-to-collection workspace with variation settings, generated episode previews, validation criteria, and source-linked dataset versions.
Teach beyond
the original demo.
A successful demonstration covers one attempt in one setting. Datarig is designed to preserve the structure of the task while expanding the situations a policy gets to learn from.
Choose the seed set
Select demonstrations or IK trajectories and associate them with the task, robot, and environment.
Define the variation
Specify the scene and task conditions to explore, along with quality checks for generated episodes.
Prepare the training collection
Review, version, and export episodes with metadata that carries through to adaptation and evaluation.
Make more of your demonstrations.
Tell us about your robot, your team, and the problem you want to solve.